


Gemini Robotics ER 2 kann auf Objekte zeigen, sie in Videos verfolgen, sie mit Begrenzungsrahmen erkennen und Bewegungstrajektorien generieren. In allen Beispielen auf dieser Seite werden Prompts in natürlicher Sprache mit generate_content verwendet.
Den vollständigen ausführbaren Code finden Sie im Robotics Cookbook.
Auf Objekte zeigen
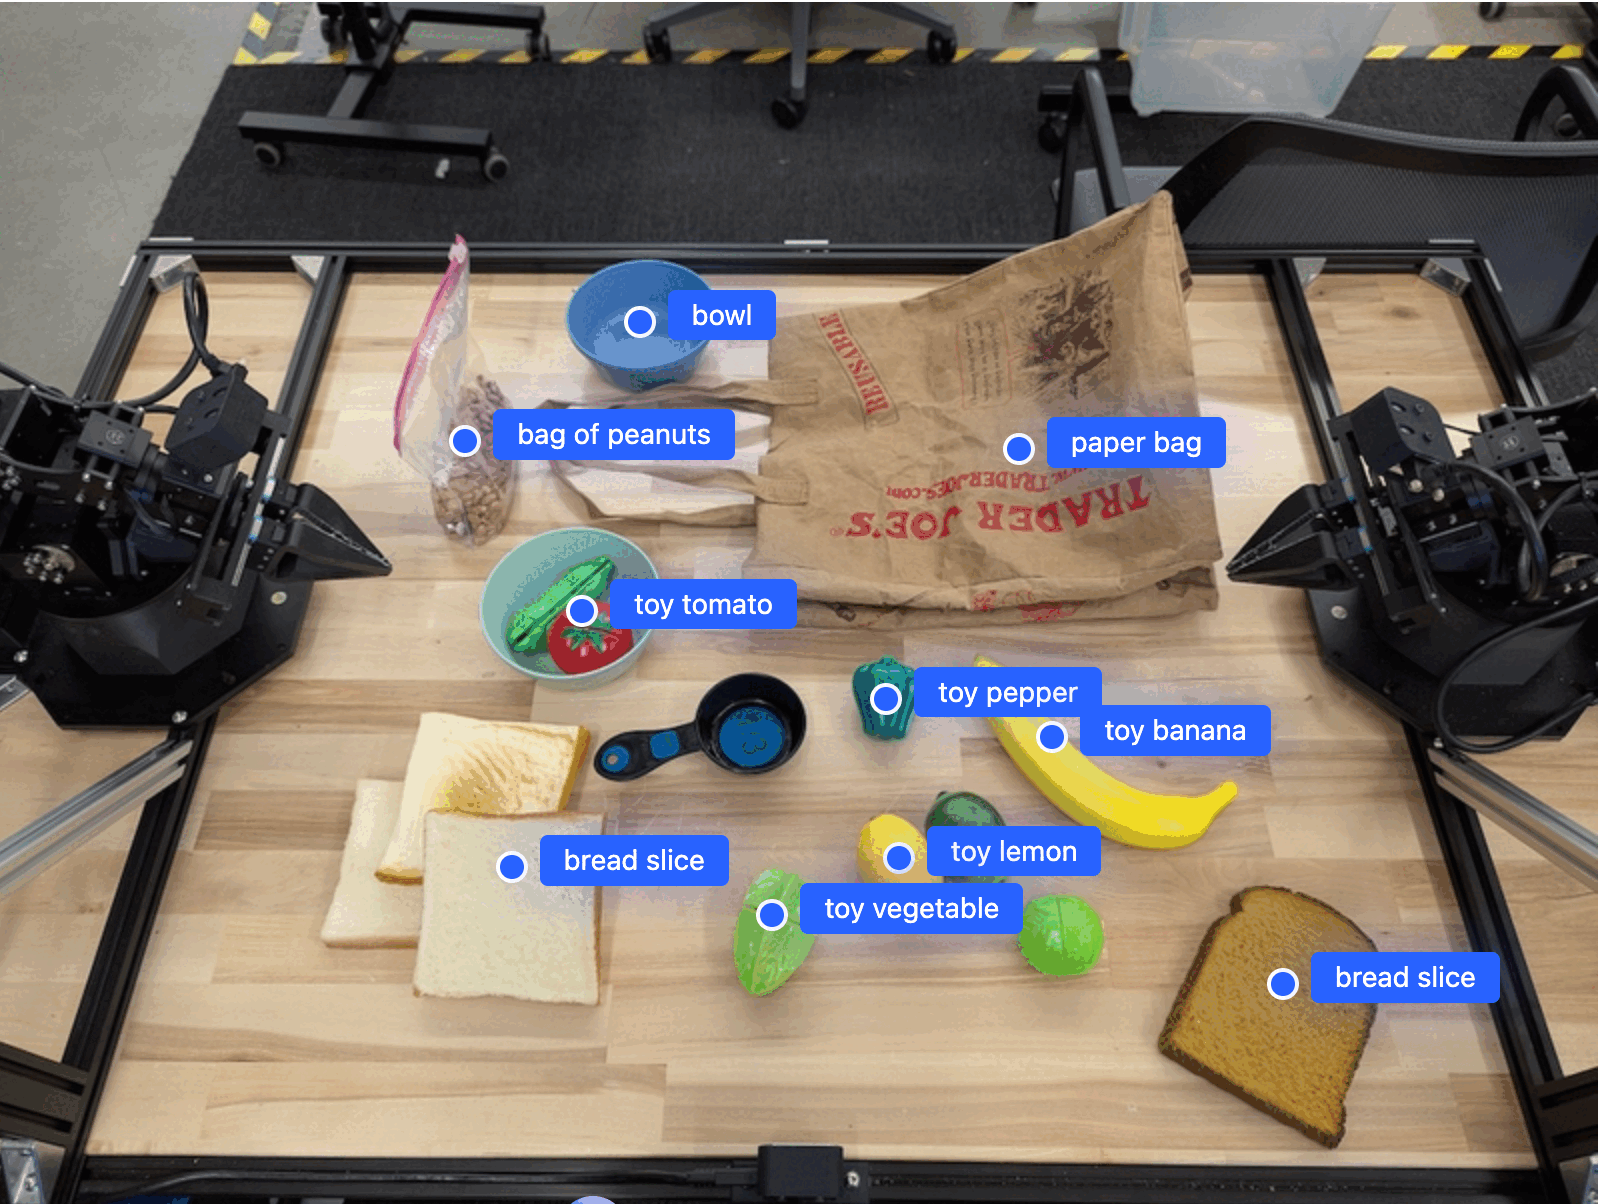
Im folgenden Beispiel werden bestimmte Objekte in einem Bild gefunden und ihre normalisierten [y, x]-Koordinaten zurückgegeben:
Python
from google import genai
from google.genai import types

PROMPT = """
          Point to no more than 10 items in the image. The label returned
          should be an identifying name for the object detected.
          The answer should follow the json format: [{"point": <point>,
          "label": <label1>}, ...]. The points are in [y, x] format
          normalized to 0-1000.
        """
client = genai.Client(
    enterprise=True,
    project="your-project-id",
    location="global",
)

# Load your image
with open("my-image.png", 'rb') as f:
    image_bytes = f.read()

image_response = client.models.generate_content(
    model="gemini-robotics-er-2-preview",
    contents=[
        types.Part.from_bytes(
            data=image_bytes,
            mime_type='image/png',
        ),
        PROMPT
    ],
    config = types.GenerateContentConfig(
        thinking_config=types.ThinkingConfig(
            thinking_level=types.ThinkingLevel.HIGH
        )
    )
)

print(image_response.text)
REST
# First, ensure you have the image file locally.
# Encode the image to base64
IMAGE_BASE64=$(base64 -w 0 my-image.png)

# Set your Google Cloud project and location.
export PROJECT_ID="your-project-id"
export LOCATION="global"
export MODEL="gemini-robotics-er-2-preview"

curl -X POST \
  "https://aiplatform.googleapis.com/v1/projects/${PROJECT_ID}/locations/${LOCATION}/publishers/google/models/${MODEL}:generateContent" \
  -H "Authorization: Bearer $(gcloud auth application-default print-access-token)" \
  -H "Content-Type: application/json" \
  -d '{
    "contents": [
      {
        "parts": [
          {
            "inlineData": {
              "mimeType": "image/png",
              "data": "'"${IMAGE_BASE64}"'"
            }
          },
          {
            "text": "Point to no more than 10 items in the image. The label returned should be an identifying name for the object detected. The answer should follow the json format: [{\"point\": [y, x], \"label\": <label1>}, ...]. The points are in [y, x] format normalized to 0-1000."
          }
        ]
      }
    ],
    "generationConfig": {
      "thinkingConfig": {
        "thinkingLevel": "HIGH"
      }
    }
  }'
Die Ausgabe ist ein JSON-Array mit Objekten, die jeweils einen point (normalisierte [y, x]-Koordinaten) und eine label zur Identifizierung des Objekts enthalten.
JSON
[
  {"point": [376, 508], "label": "small banana"},
  {"point": [287, 609], "label": "larger banana"},
  {"point": [223, 303], "label": "pink starfruit"},
  {"point": [435, 172], "label": "paper bag"},
  {"point": [270, 786], "label": "green plastic bowl"},
  {"point": [488, 775], "label": "metal measuring cup"},
  {"point": [673, 580], "label": "dark blue bowl"},
  {"point": [471, 353], "label": "light blue bowl"},
  {"point": [492, 497], "label": "bread"},
  {"point": [525, 429], "label": "lime"}
]
Die folgende Abbildung zeigt ein Beispiel dafür, wie diese Punkte dargestellt werden können:
Objekte in einem Video verfolgen
Gemini Robotics ER 2 kann auch Videoframes analysieren, um Objekte im Zeitverlauf zu verfolgen.
Python
from google import genai
from google.genai import types

client = genai.Client(
    enterprise=True,
    project="your-project-id",
    location="global",
)

# Load your video
with open("my-video.mp4", 'rb') as f:
    video_bytes = f.read()

prompt = """
          Point to the red ball in every frame where it appears.
          The answer should follow the json format: [{"point": [y, x],
          "label": <label>}, ...]. The points are in [y, x] format
          normalized to 0-1000. Return one entry per frame that contains
          the object.
        """

image_response = client.models.generate_content(
  model="gemini-robotics-er-2-preview",
  contents=[
    types.Part.from_bytes(
      data=video_bytes,
      mime_type='video/mp4',
    ),
    prompt
  ],
  config = types.GenerateContentConfig(
      thinking_config=types.ThinkingConfig(
          thinking_level=types.ThinkingLevel.HIGH
      )
  )
)

print(image_response.text)
Objekterkennung und Begrenzungsrahmen
Zusätzlich zu Punkten können Sie das Modell auffordern, 2D-Begrenzungsrahmen zurückzugeben, die mehr räumliche Details für erkannte Objekte liefern.
Python
from google import genai
from google.genai import types

client = genai.Client(
    enterprise=True,
    project="your-project-id",
    location="global",
)

with open("my-image.png", 'rb') as f:
    image_bytes = f.read()

prompt = """
          Detect all objects in this image and return bounding boxes.
          The answer should follow the JSON format:
          [{"label": <label>, "y": <y_min>, "x": <x_min>,
            "y2": <y_max>, "x2": <x_max>}, ...]
          where coordinates are normalized to 0-1000.
        """

image_response = client.models.generate_content(
  model="gemini-robotics-er-2-preview",
  contents=[
    types.Part.from_bytes(
      data=image_bytes,
      mime_type='image/png',
    ),
    prompt
  ],
  config = types.GenerateContentConfig(
      thinking_config=types.ThinkingConfig(
          thinking_level=types.ThinkingLevel.LOW
      )
  )
)

print(image_response.text)
Verläufe
Gemini Robotics ER 2 kann Sequenzen von Punkten generieren, die eine Trajektorie definieren, was für die Steuerung von Roboterbewegungen nützlich ist.
In diesem Beispiel wird eine Trajektorie angefordert, um einen roten Stift in einen Organizer zu bewegen, einschließlich einer Schätzung der Zwischenwegpunkte. Der Code wurde reduziert, sodass nur die Aufforderung angezeigt wird.
Python
prompt = """
          Generate a trajectory for the robotic arm to pick up the red pen
          and place it in the organizer. Return a list of waypoints as JSON:
          [{"step": <int>, "point": [y, x], "action": <description>}, ...]
          where coordinates are normalized to 0-1000.
        """
Platz für einen Laptop schaffen
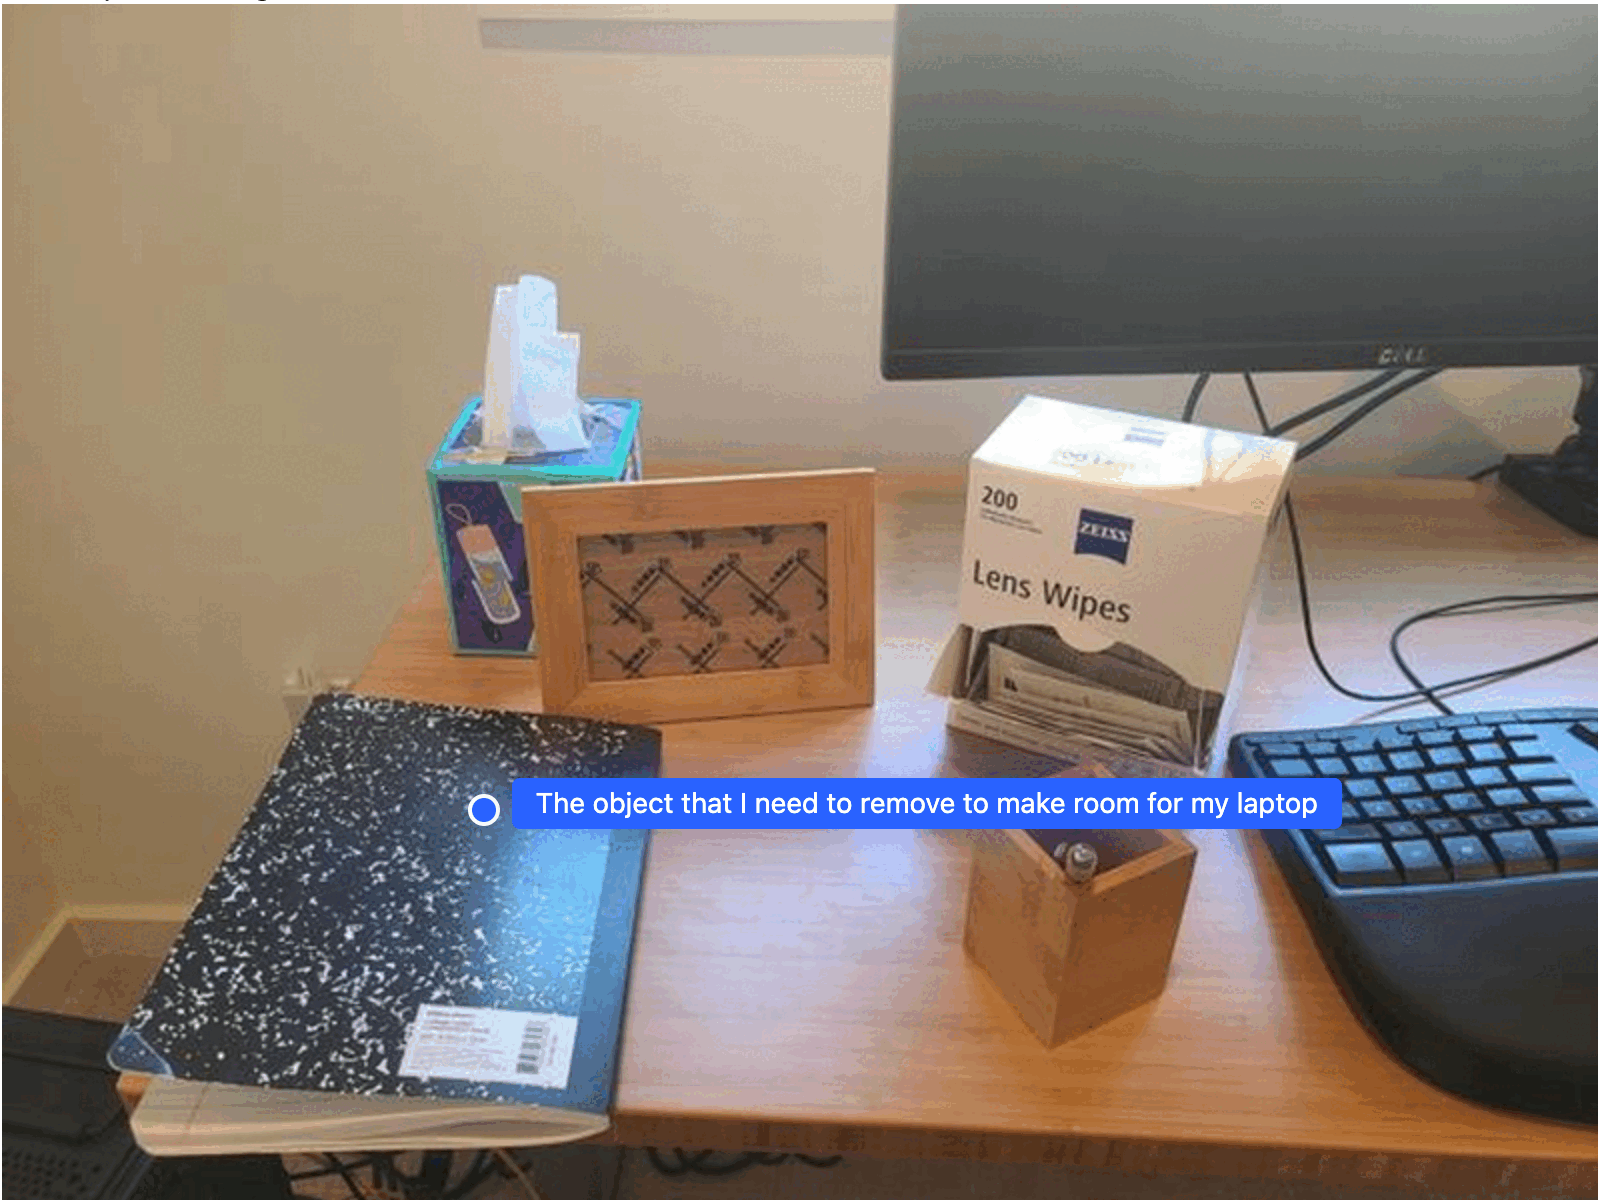
Dieses Beispiel zeigt, wie Gemini Robotics ER 2 über einen Raum nachdenken kann. Der Prompt fordert das Modell auf, zu ermitteln, welches Objekt verschoben werden muss, um Platz für ein anderes Element zu schaffen.
Python
from google import genai
from google.genai import types

client = genai.Client(
    enterprise=True,
    project="your-project-id",
    location="global",
)

# Load your image
with open('path/to/image-with-objects.jpg', 'rb') as f:
    image_bytes = f.read()

prompt = """
          Point to the object that I need to remove to make room for my laptop
          The answer should follow the JSON format: [{"point": <point>,
          "label": <label1>}, ...]. The points are in [y, x] format normalized to 0-1000.
        """

image_response = client.models.generate_content(
  model="gemini-robotics-er-2-preview",
  contents=[
    types.Part.from_bytes(
      data=image_bytes,
      mime_type='image/jpeg',
    ),
    prompt
  ],
  config = types.GenerateContentConfig(
      thinking_config=types.ThinkingConfig(
          thinking_level=types.ThinkingLevel.HIGH
      )
  )
)

print(image_response.text)
Die Antwort enthält eine 2D-Koordinate des Objekts, das die Frage des Nutzers beantwortet, in diesem Fall das Objekt, das bewegt werden soll, um Platz für einen Laptop zu schaffen.
[
  {"point": [672, 301], "label": "The object that I need to remove to make room for my laptop"}
]
Lunchpaket packen
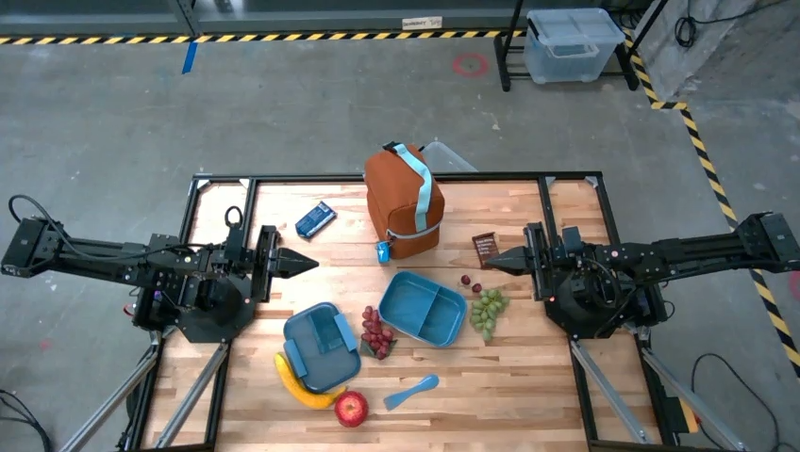
Das Modell kann auch Anleitungen für mehrstufige Aufgaben bereitstellen und auf relevante Objekte für jeden Schritt verweisen. In diesem Beispiel wird gezeigt, wie das Modell eine Reihe von Schritten zum Packen einer Lunchbox plant.
Python
from google import genai
from google.genai import types

client = genai.Client(
    enterprise=True,
    project="your-project-id",
    location="global",
)

# Load your image and set up your prompt
with open('path/to/image-of-lunch.jpg', 'rb') as f:
    image_bytes = f.read()

prompt = """
          Explain how to pack the lunch box and lunch bag. Point to each
          object that you refer to. Each point should be in the format:
          [{"point": [y, x], "label": }], where the coordinates are
          normalized between 0-1000.
        """

image_response = client.models.generate_content(
  model="gemini-robotics-er-2-preview",
  contents=[
    types.Part.from_bytes(
      data=image_bytes,
      mime_type='image/jpeg',
    ),
    prompt
  ],
  config = types.GenerateContentConfig(
      thinking_config=types.ThinkingConfig(
          thinking_level=types.ThinkingLevel.HIGH
      )
  )
)

print(image_response.text)
Die Antwort auf diesen Prompt ist eine detaillierte Anleitung zum Packen einer Lunchbox anhand der Bildeingabe.
Eingabebild
Modellausgabe
Based on the image, here is a plan to pack the lunch box and lunch bag:

1.  **Pack the fruit into the lunch box.** Place the apple, banana, red grapes, and green grapes into the blue lunch box.
2.  **Add the spoon to the lunch box.** Put the blue spoon inside the lunch box as well.
3.  **Close the lunch box.** Secure the lid on the blue lunch box.
4.  **Place the lunch box inside the lunch bag.** Put the closed blue lunch box into the brown lunch bag.
5.  **Pack the remaining items into the lunch bag.** Place the blue snack bar and the brown snack bar into the brown lunch bag.

Here is the list of objects and their locations:
*   [{"point": [899, 440], "label": "apple"}]
*   [{"point": [814, 363], "label": "banana"}]
*   [{"point": [727, 470], "label": "red grapes"}]
*   [{"point": [675, 608], "label": "green grapes"}]
*   [{"point": [706, 529], "label": "blue lunch box"}]
*   [{"point": [864, 517], "label": "blue spoon"}]
*   [{"point": [499, 401], "label": "blue snack bar"}]
*   [{"point": [614, 705], "label": "brown snack bar"}]
*   [{"point": [448, 501], "label": "brown lunch bag"}]
Nächste Schritte
Weitere Informationen zu Gemini Robotics ER 2 finden Sie in den folgenden Ressourcen:
- Agentische Funktionen: Code-Ausführung, Instrumentenablesung und Bildannotation.
- Aufgabenorchestrierung: Langfristige Aufgaben mit benutzerdefinierten Roboter-APIs.
- Videoverständnis: Momentfindung und Fortschrittsklassifizierung.
- Gemini Robotics ER 2 – Übersicht: Funktionen und Kurzanleitung.
- Informationen zum Gemini Robotics ER 2-Modell: technische Daten, Tokenlimits und unterstützte Funktionen.