


Gemini Robotics ER 2 kann Aufgaben planen und räumliche Zusammenhänge erkennen. So kann es ableiten, welche Aktionen ausgeführt und welche Objekte bewegt werden müssen, um ein Ziel zu erreichen. Auf dieser Seite finden Sie ein Beispiel für die Ausführung eines Pick-and-Place-Vorgangs über eine benutzerdefinierte Roboter-API, um die Aufgabe zu orchestrieren, einen Gegenstand in eine Schüssel zu legen.
Den vollständigen ausführbaren Code finden Sie im Robotics Cookbook.
Benutzerdefinierte Roboter-API aufrufen
In diesem Beispiel wird die Aufgabenorchestrierung mit einer benutzerdefinierten Roboter-API veranschaulicht. Es wird eine Mock-API für einen Pick-and-Place-Vorgang eingeführt. Die Aufgabe besteht darin, einen blauen Block aufzunehmen und in eine orangefarbene Schüssel zu legen:
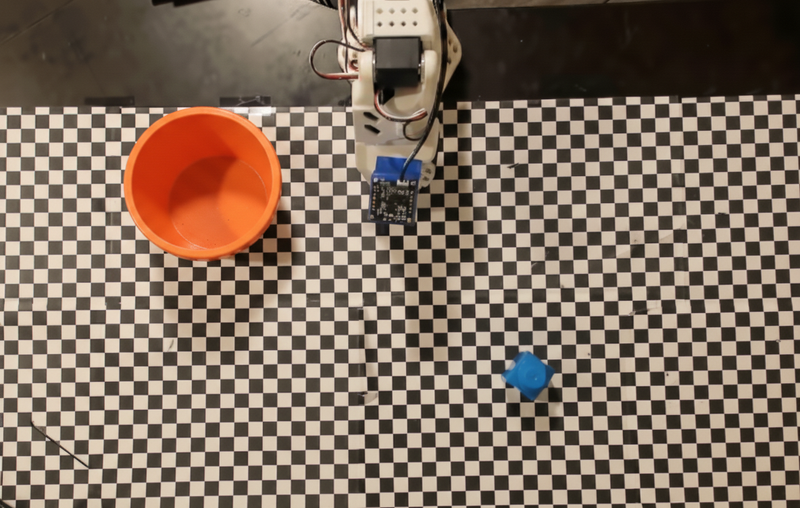
In diesem Beispiel werden die folgenden Mock-Robot-API- und Tooldefinitionen verwendet. Anstatt die Abfolge von Aktionen als Text zurückzugeben, ruft das Modell diese Funktionen über die Funktionsaufrufschnittstelle des Google Gen AI SDK auf:
Python
from google import genai
from google.genai import types

client = genai.Client(
    enterprise=True,
    project="your-project-id",
    location="global",
)

def move(x, y, high):
    print(f"Mock Robot: Moving to coordinates: {x}, {y}, {'high above table' if high else 'down at table level'}")

def setGripperState(opened):
    print(f"Mock Robot: {'Opening gripper' if opened else 'Closing gripper'}")

robot_origin_y = 300
robot_origin_x = 500

move_declaration = types.FunctionDeclaration(
    name="move",
    description="Moves the arm to the given coordinates.",
    parameters=types.Schema(
        type=types.Type.OBJECT,
        properties={
            "x": types.Schema(type=types.Type.INTEGER, description="X coordinate relative to the origin"),
            "y": types.Schema(type=types.Type.INTEGER, description="Y coordinate relative to the origin"),
            "high": types.Schema(type=types.Type.BOOLEAN, description="Set to True to lift the robot arm above the scene. Set to False to place the gripper on the surface."),
        },
        required=["x", "y", "high"],
    ),
)

set_gripper_state_declaration = types.FunctionDeclaration(
    name="setGripperState",
    description="Opens or closes the robot's gripper.",
    parameters=types.Schema(
        type=types.Type.OBJECT,
        properties={
            "opened": types.Schema(type=types.Type.BOOLEAN, description="True opens the gripper, False closes the gripper."),
        },
        required=["opened"],
    ),
)

robot_tools = types.Tool(function_declarations=[move_declaration, set_gripper_state_declaration])
Im folgenden Beispiel werden der Prompt und das Bild zusammen mit den Tooldefinitionen an das Modell gesendet. Anschließend wird eine Agentenschleife ausgeführt: Nach jeder Modellantwort werden alle angeforderten Funktionsaufrufe (move, setGripperState) ausgeführt, die Ergebnisse an das Modell zurückgesendet und der Vorgang wiederholt, bis das Modell keine Funktionen mehr aufruft oder das Schrittlimit erreicht ist.
Python
with open("robot-api-example.png", "rb") as f:
    img_bytes = f.read()

prompt = (
    "You are a robotic arm with six degrees-of-freedom. "
    f"The origin point for calculating the moves is at normalized point y={robot_origin_y}, x={robot_origin_x}. "
    "Use this as the new (0,0) for calculating moves, allowing x and y to be negative.\n\n"
    "Find the blue block and the orange bowl. Calculate their coordinates relative to the origin.\n"
    "Perform a pick and place operation where you pick up the blue block and place it into the orange bowl. "
    "Call the appropriate sequence of functions to complete this operation."
)

contents = [
    types.Content(role="user", parts=[
        types.Part.from_bytes(data=img_bytes, mime_type="image/png"),
        types.Part(text=prompt),
    ])
]

print("\n--- Executing Orchestrated Plan ---")

max_steps = 15  # Safety limit to prevent infinite loops
step_count = 0

# The agentic loop
while step_count < max_steps:
    step_count += 1

    response = client.models.generate_content(
        model="gemini-robotics-er-2-preview",
        contents=contents,
        config=types.GenerateContentConfig(
            tools=[robot_tools],
            thinking_config=types.ThinkingConfig(
                thinking_level=types.ThinkingLevel.LOW
            ),
        ),
    )

    # Add the model response to the conversation history
    contents.append(response.candidates[0].content)

    # Check for function calls
    function_calls = [
        part for part in response.candidates[0].content.parts if part.function_call
    ]

    if not function_calls:
        # The model is done calling functions
        print("Sequence complete.")
        print(f"Model Summary: {response.text}")
        break

    # Execute function calls and collect results
    function_response_parts = []
    for part in function_calls:
        fc = part.function_call
        if fc.name == "move":
            move(**fc.args)
        elif fc.name == "setGripperState":
            setGripperState(**fc.args)

        function_response_parts.append(
            types.Part.from_function_response(
                name=fc.name,
                response={"status": "success"},
            )
        )

    # Send the function results back to the model
    contents.append(types.Content(role="user", parts=function_response_parts))
Im Folgenden sehen Sie eine mögliche Ausgabe des Modells basierend auf dem Prompt und der simulierten Roboter-API. Die Ausgabe enthält die Ergebnisse der Roboterfunktionsaufrufe, die das Modell nacheinander ausgeführt hat:
--- Executing Orchestrated Plan ---
Mock Robot: Opening gripper
Mock Robot: Moving to coordinates: 160, 440, high above table
Mock Robot: Moving to coordinates: 160, 440, down at table level
Mock Robot: Closing gripper
Mock Robot: Moving to coordinates: 160, 440, high above table
Mock Robot: Moving to coordinates: -250, 60, high above table
Mock Robot: Moving to coordinates: -250, 60, down at table level
Mock Robot: Opening gripper
Mock Robot: Moving to coordinates: -250, 60, high above table
Sequence complete.
Model Summary: I have completed the task of picking up the blue block and placing it into the orange bowl.
Nächste Schritte
Weitere Informationen zu Gemini Robotics ER 2 finden Sie in den folgenden Ressourcen:
- Videoverständnis: Aufgabenfortschritt anhand von Videos verfolgen.
- Räumliches Denken: Beispiele für Zeigen, Tracking und Begrenzungsrahmen.
- Agentische Funktionen: Code-Ausführung, Instrumentenablesung und Bildannotation.
- Gemini Robotics ER 2 – Übersicht: Funktionen und Kurzanleitung.
- Informationen zum Gemini Robotics ER 2-Modell: technische Daten, Tokenlimits und unterstützte Funktionen.